Gemini 2.5 for robotics and embodied intelligence- Google Developers Blog
Jun 24, 2025Laura Graesser, Fei Xia
Summary
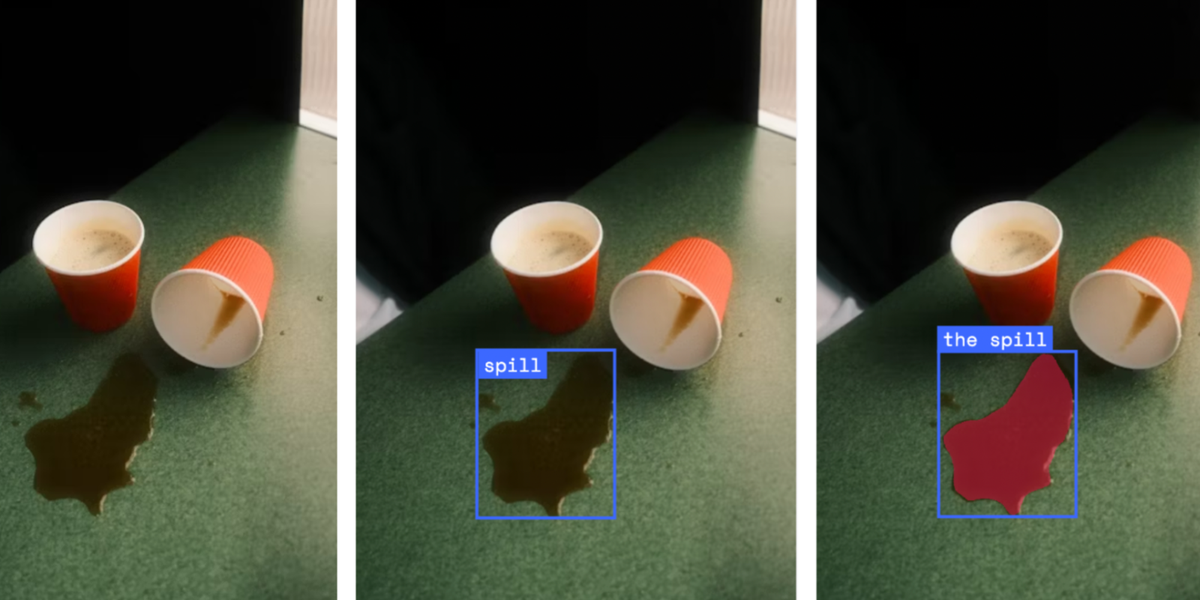
This post details how Gemini 2.5 models, including Gemini Robotics-ER, can be used for robotics and embodied intelligence. It provides practical examples and prompts for semantic scene understanding (object identification, restocking needs, gauge reading), tracking multiple objects, detecting open-ended concepts like 'spill', and generating robot arm trajectories. It also demonstrates using Gemini 2.5 with a robot control API for code generation to perform pick-and-place tasks with different strategies, and shows how in-context examples can be used for more dexterous robot control tasks like packing boxes and folding a dress.
More from the Coral Edge AI Platform trail
- ML Drift: Next-Gen GPU AI/ML Inference at the Edge- Google Developers Blog
- Bring multimodal semantic search to the edge with EmbeddingGemma 2- Google Developers Blog
- EmbeddingGemma 2: The Developer Guide- Google Developers Blog
- Mastering Edge AI on Raspberry Pi with LiteRT and Gemma- Google Developers Blog
- LiteRT.js, Google's high performance Web AI Inference- Google Developers Blog