One Model, Any Scenario: End-to-end Locomotion from Vision
Aug 5, 2025
Summary
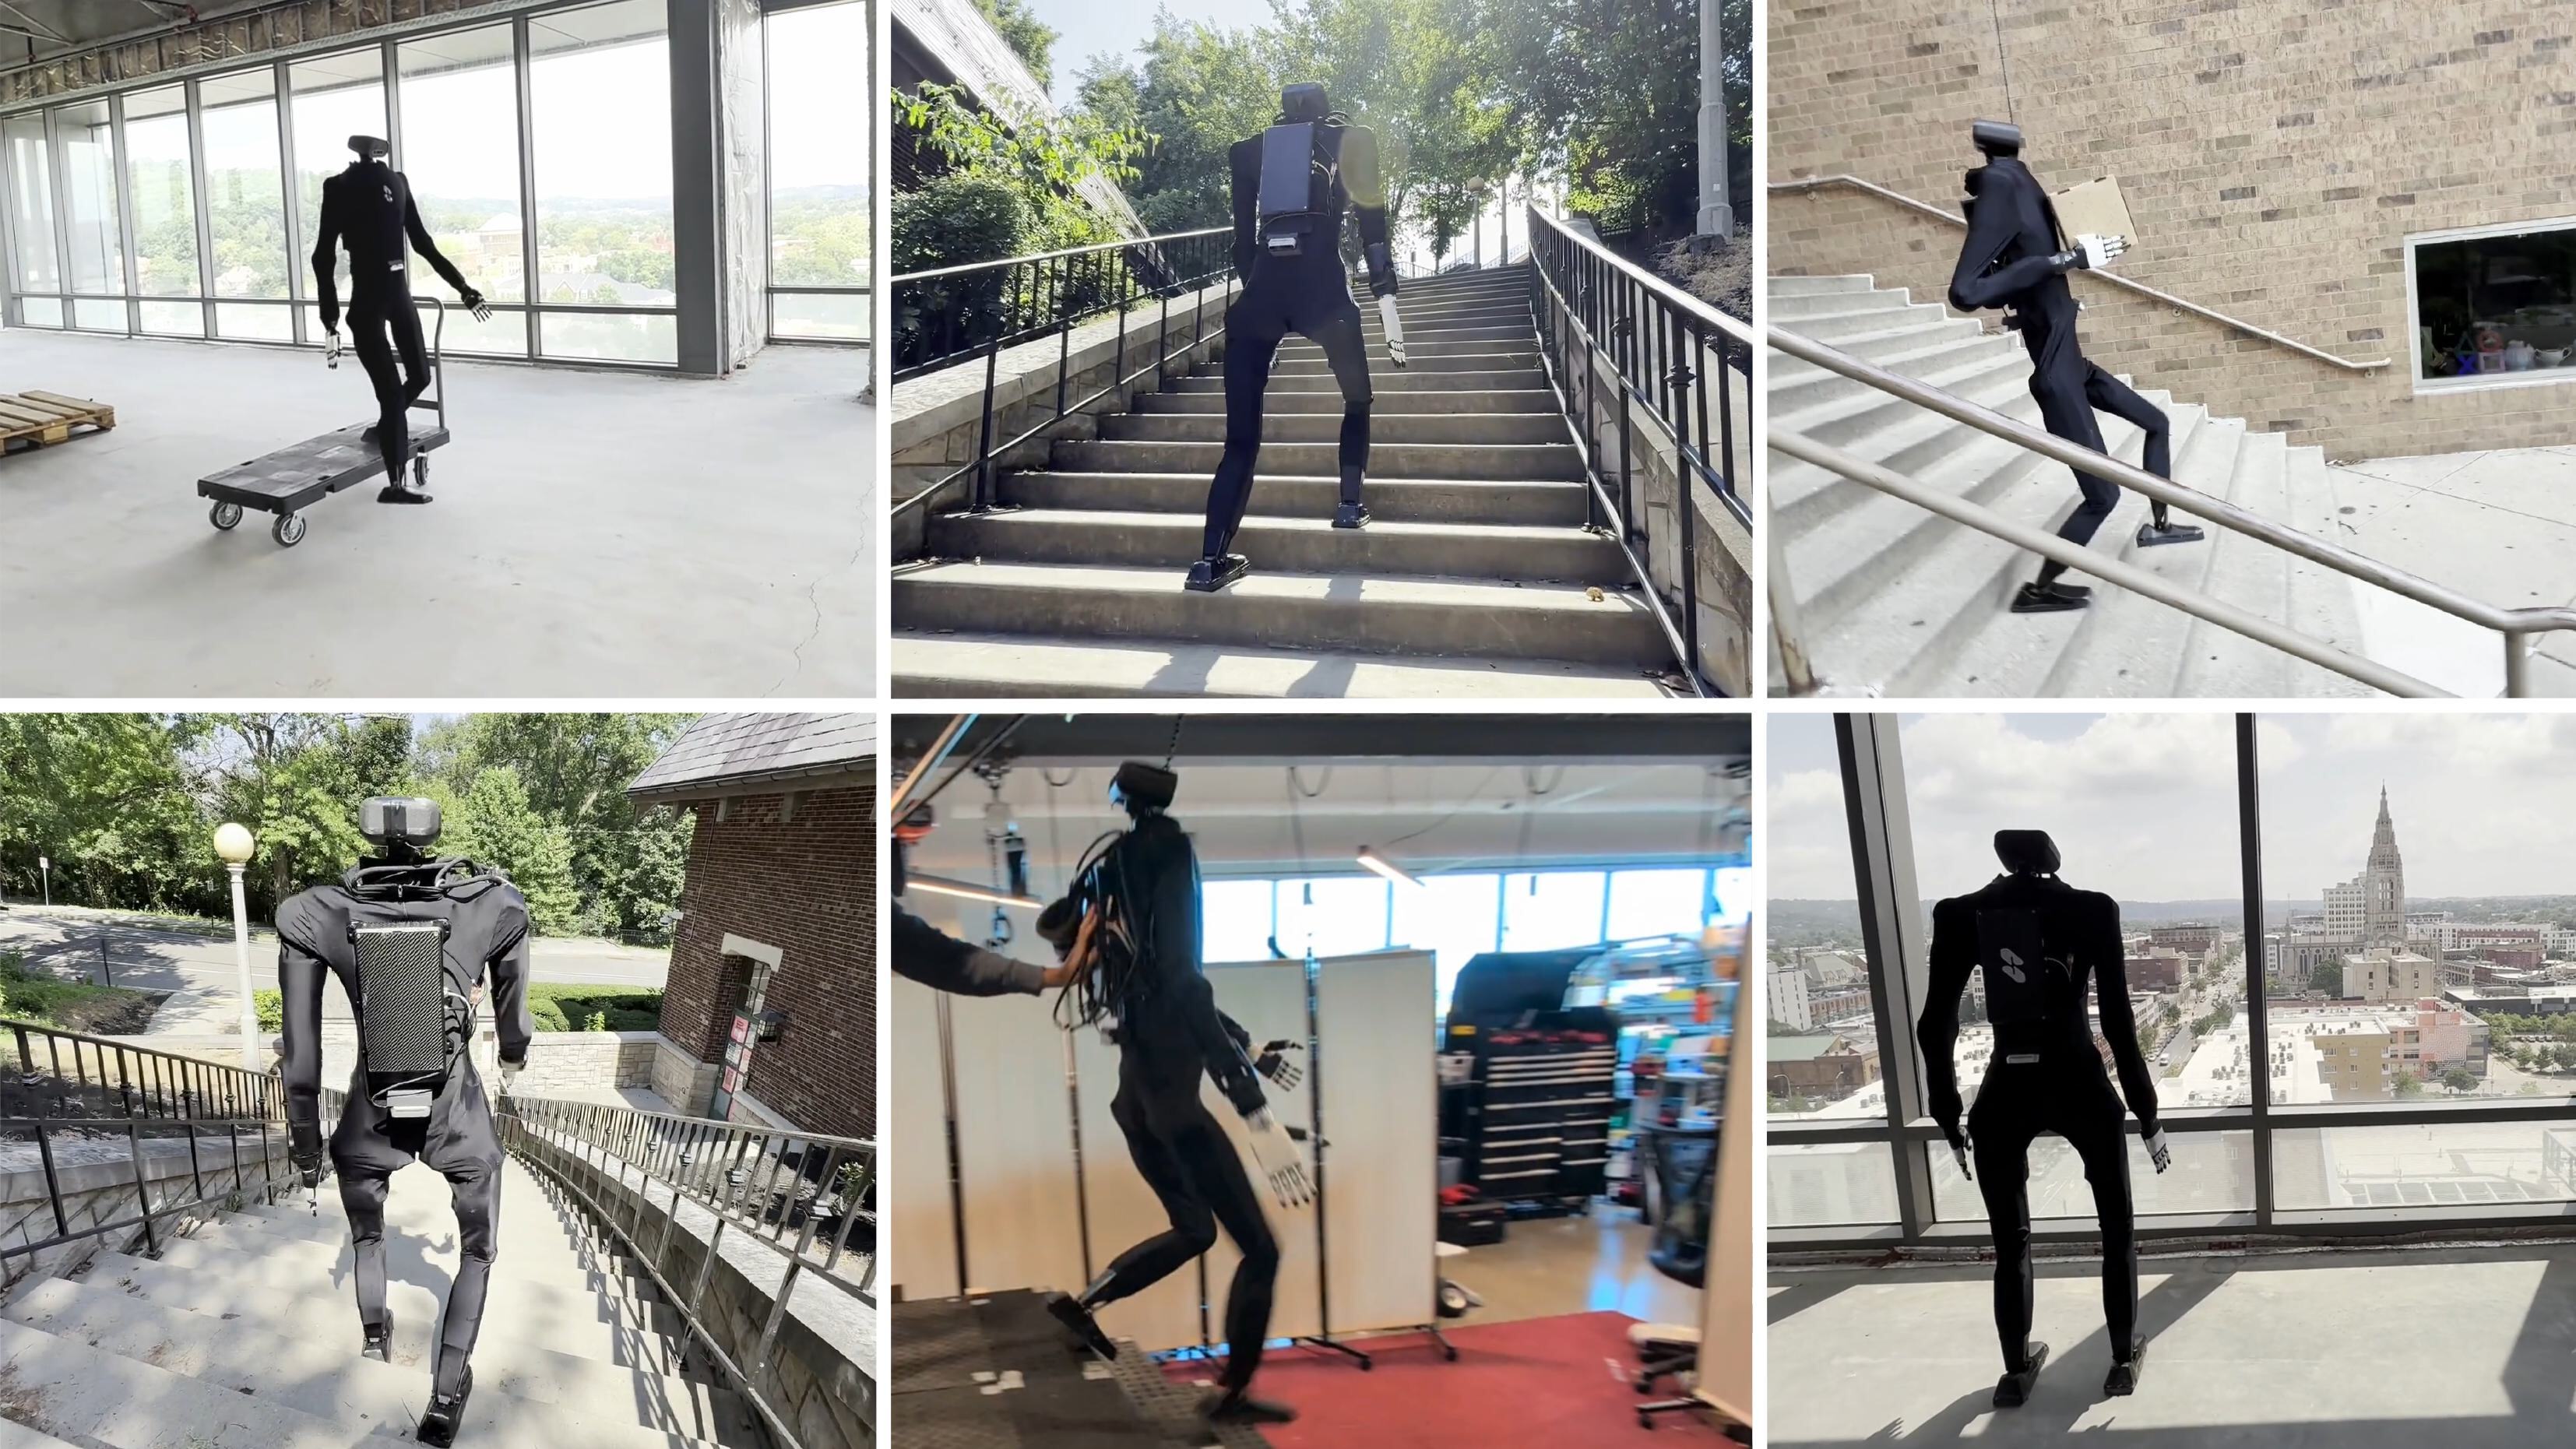
This post details the low-level control capabilities of Skild Brain, a general vision-based robot model. It introduces a single neural network that directly outputs low-level motor commands from raw images and joint feedback, enabling end-to-end locomotion control driven by online vision and proprioception. The model demonstrates dynamic adaptation to new terrain, including stairs and obstacles, without prior planning or mapping, and shows robustness to external forces and precision in foot placement, even when carrying payloads.