Natural Humanoid Walk Using Reinforcement Learning
Mar 25, 2025
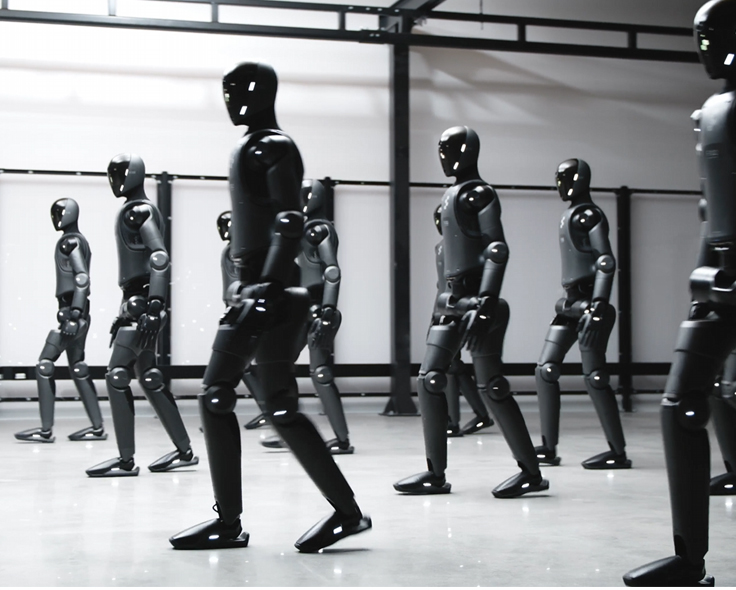
Summary
This post details the application of end-to-end reinforcement learning (RL) trained in simulation to achieve natural humanoid walking for the Figure 02 robot. It highlights the use of high-fidelity physics simulation with domain randomization and kHz-rate torque feedback for zero-shot sim-to-real transfer. The approach incorporates reward shaping to mimic human walking gait attributes (heel-strikes, toe-offs, arm-swing) while optimizing for velocity tracking, power consumption, and robustness to perturbations. The engineering effort focuses on bridging the sim-to-real gap to enable repeatable, human-like walking across the robot fleet.