Helix 02 Bedroom Tidy
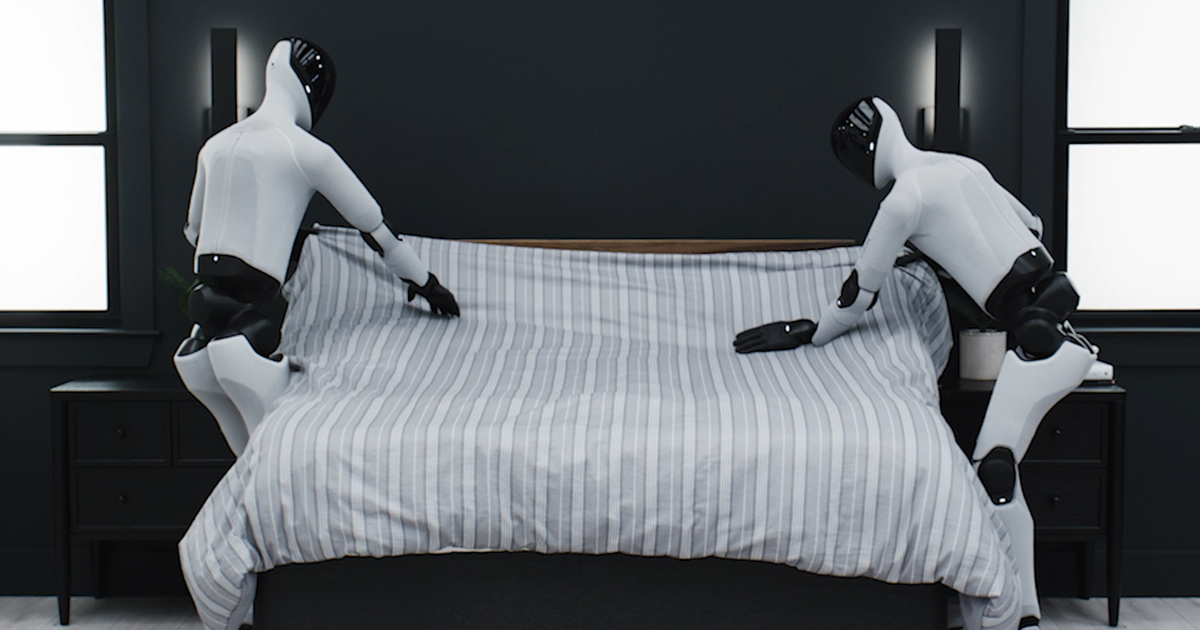
This post demonstrates the application of the Helix-02 VLA model to a complex collaborative task: resetting a bedroom. It showcases the model's ability to perform multi-humanoid locomanipulation directly from pixels to actions using a single learned neural network. Key advancements include opening doors with whole-body coordination, pushing furniture using stance and balance, draping clothing onto narrow fixtures, placing objects with in-hand reorientation, closing a book with dexterous bimanual control, operating a trash can foot pedal with single-leg balance, coordinating two humanoids around a shared deformable object (a comforter), and manipulating bedding with bimanual whole-body motions. The post highlights the challenges of multi-robot interaction, deformable object manipulation, and real-time decision-making in a shared environment, emphasizing that the core algorithm remained unchanged, with new data driving the expanded capabilities.