Helix Accelerating Real-World Logistics
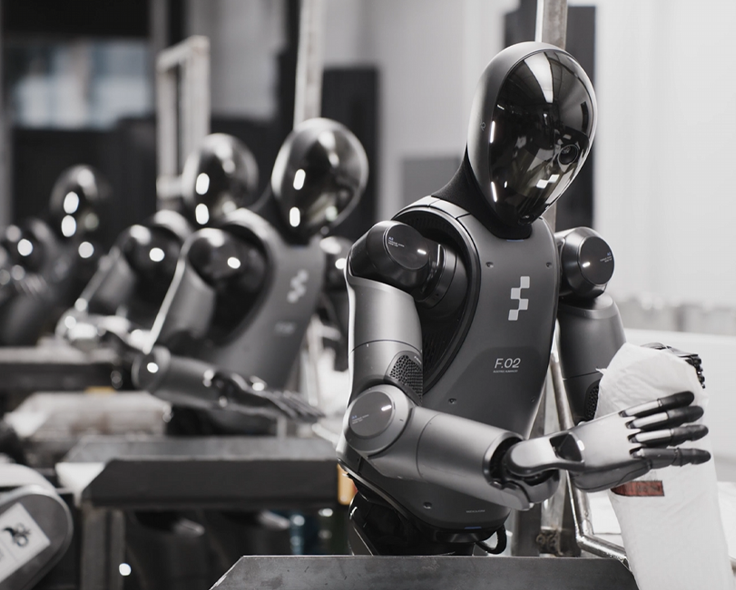
This post details improvements to Helix's System 1 (visuo-motor control policy) for real-world logistics package manipulation. Key contributions include: 1) Integration of stereo vision and a multiscale feature extraction network for richer 3D understanding and improved robustness to package variations, leading to a 60% increase in throughput over non-stereo baselines. 2) A learned visual proprioception model for online self-calibration, enabling strong cross-robot policy transfer despite hardware variations. 3) Emphasis on data quality over quantity, showing curated demonstrations yield significantly better throughput. 4) A test-time speed-up technique ('Sport Mode') that interpolates action chunk outputs, achieving up to 50% speedup with minimal performance degradation and increasing effective throughput beyond expert trajectories.